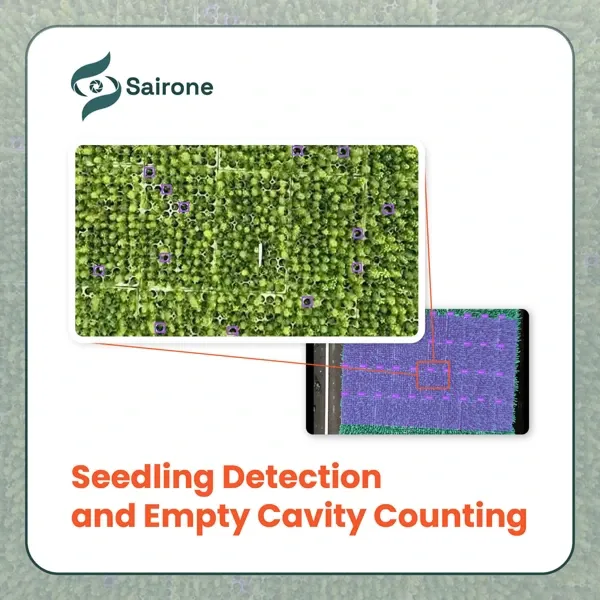
Seedling Detection and Empty Cavity Counting
Development
May 24, 2026
Aug 10, 2026
Nursery and greenhouse propagation operations often rely on manual inspection methods to evaluate seedling trays, detect empty cavities, and monitor propagation quality. These workflows are labor-intensive, time-consuming, and difficult to scale consistently across large production environments.
To address these challenges, Saiwa collaborated with GreenTech to investigate the use of drone-based imagery and machine learning models for automated tray analysis. The project focused on two primary objectives:
Propagation facilities and nursery operations commonly face operational challenges related to tray inspection, seedling monitoring, and propagation quality assessment. In many commercial greenhouse and nursery environments, these tasks are still performed manually by staff who visually inspect thousands of trays to identify empty cavities, evaluate seedling emergence, and monitor overall tray uniformity. As production scale increases, manual counting and inspection workflows become increasingly time-consuming, labor-intensive, and difficult to standardize consistently across large propagation areas. Variability in lighting conditions, plant density, tray alignment, and human interpretation can also affect counting accuracy and reduce operational efficiency. These limitations create a strong need for scalable, data-driven monitoring solutions capable of providing faster and more consistent propagation analysis across large nursery operations.
Saiwa developed a multi-stage AI-powered image analysis workflow specifically designed for propagation tray assessment and cavity detection.
The first stage focused on detecting and localizing seedling blocks within drone imagery. To train the detection models, Saiwa’s team annotated high-resolution images using the Fraime boundary annotation service. These annotated datasets were used to train machine learning models capable of identifying tray boundaries and propagation blocks across aerial imagery.
After tray localization, the second stage focused on identifying and counting empty cavities within each propagation block. For this step, we annotated images using Fraime bounding-box annotation service. The AI models were then trained to detect empty pots within trays.
The primary goal of the project was to automate nursery tray analysis using AI-powered computer vision models and drone imagery. Specific objectives included:
The project successfully demonstrated promising results for both tray localization and empty cavity detection. Results generated on previously unseen imagery showed that the machine learning models were capable of accurately identifying propagation blocks and detecting empty cells across seedling trays.
Collaboration with
Windward Drones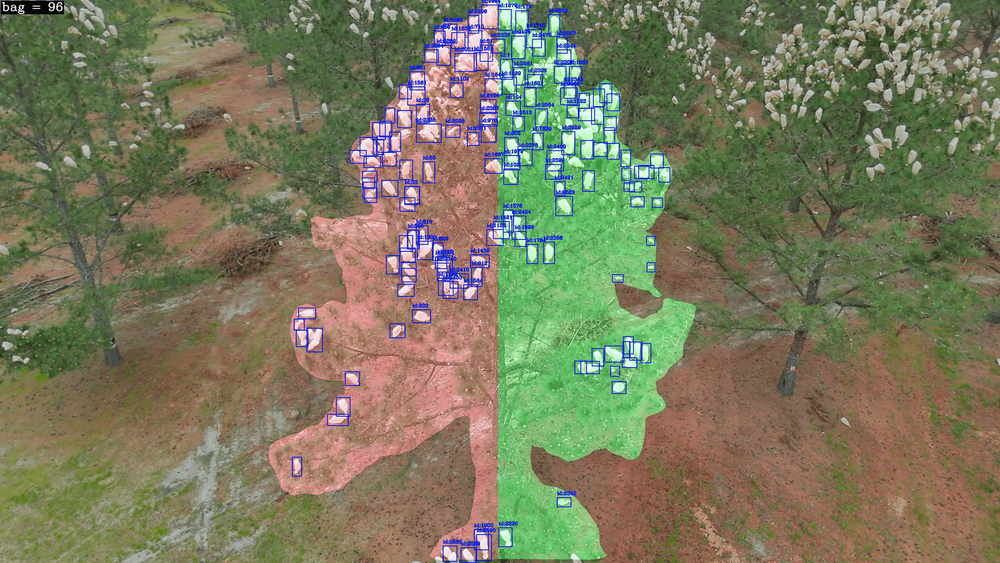
Funded by
Ontario Centre of Innovation (OCI)
Collaboration with
Paramoria Agri-Science Inc